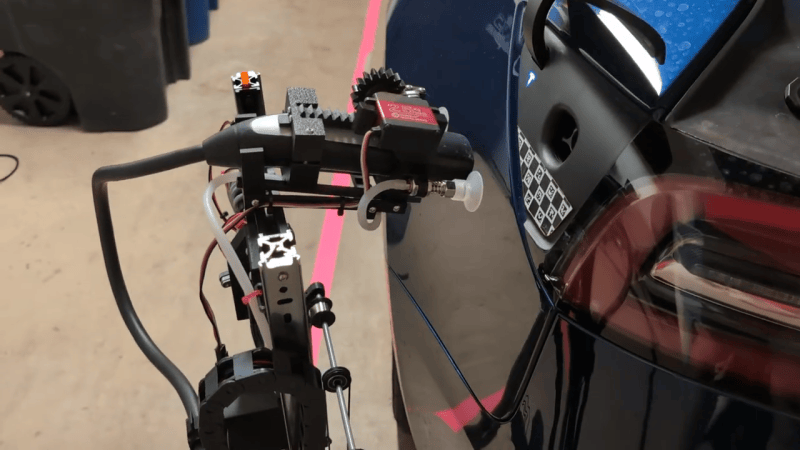
Not only does [Mew463]’s robotic car charger take care of plugging in his vehicle for him, it has some really clever features that are great to see in action.
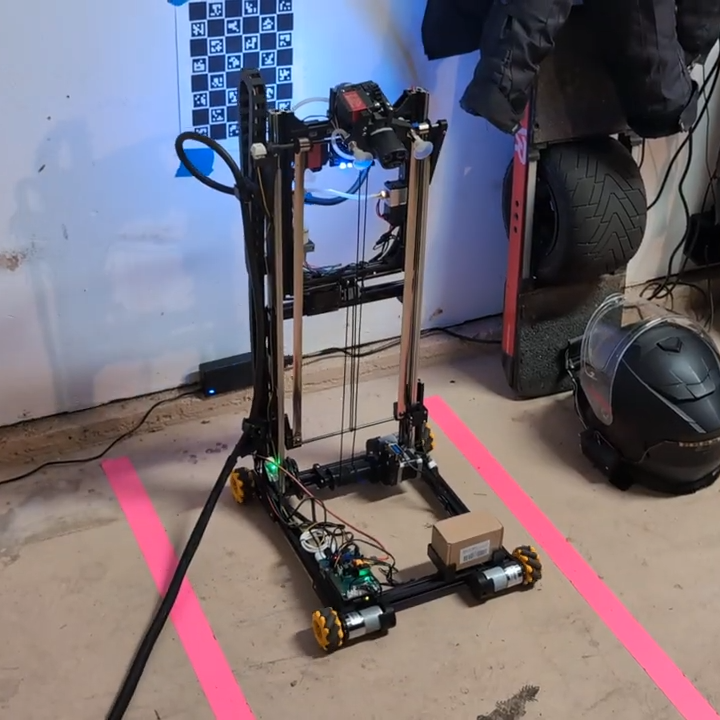 We’ve seen a rover-platform-based robotic car charger before, but what’s different here is that [Mew463]’s robot isn’t particularly husky. It’s designed to be low-profile, snug right up against the vehicle during use, and park itself against the wall when not.
As an added touch, one doesn’t even have to manually open the car’s charge port door. The robot uses API calls that — once it confirms the vehicle is parked and not in use — unlocks and opens the charge port remotely. People used to be able to pop the charge port with a plain old wireless replay attack, but an API is the better way to go about it.
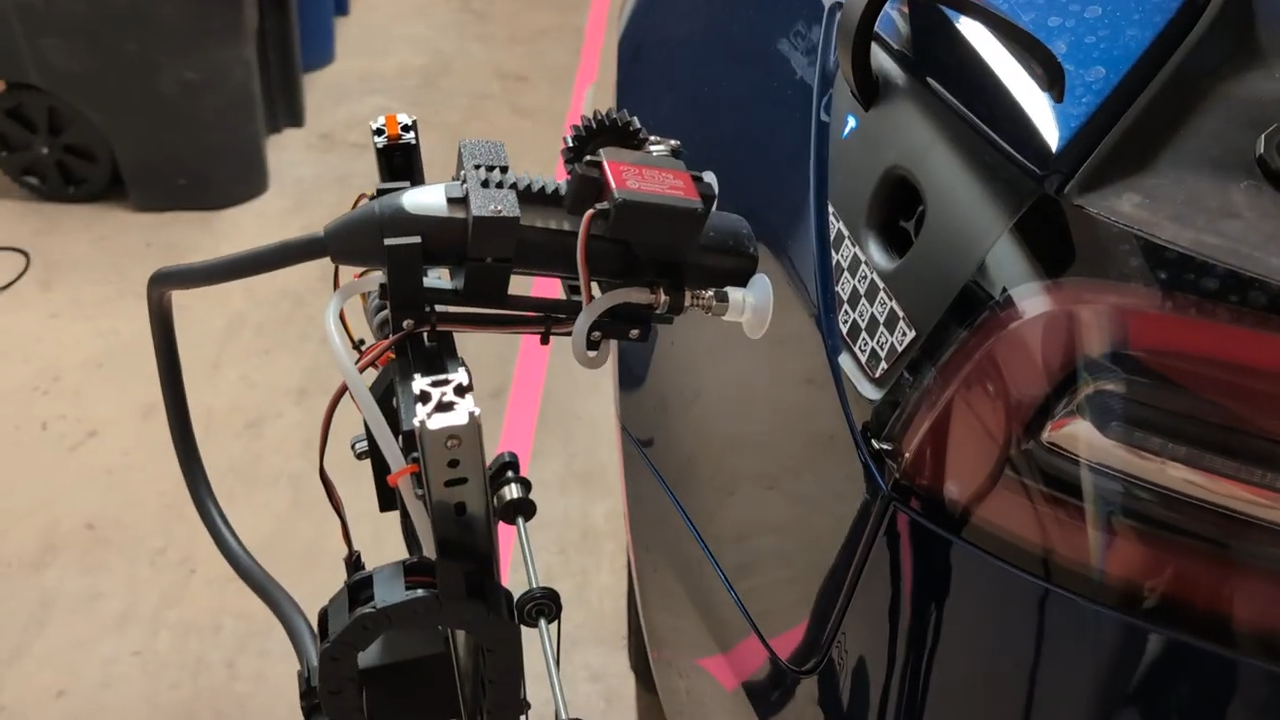
Four Mecanum wheel and LiDAR get the robot into more or less the right position, then fine-tuning happens with the help of an onboard camera and a ChARuco board pattern on the car just under the charging port.
Once things are lined up just right, the charger moves forward to plug into the car. Here’s where [Mew463] had to get clever, because plugging in a car charger actually takes a decent amount of force, and the robot is not particularly heavy. The solution is two suction cups that anchor the robot to the car as a gear assembly pushes the charger home. We really like how the robot snugs right up, so while the car is charging there isn’t a big thing in the way.
Disconnecting is the reverse of the process, and for the robot to park itself again it simply swivels the camera backward so it can see the marker on the wall without the whole robot having to turn around. It’s all very slick, and you can watch it in action in the video embedded below.